Derek Fan

M.S. in Mechanical Engineering • Carnegie Mellon University
I’ve worked at every level of the robot control stack, ranging from low-level motor drivers to high-level planning and policy training. My experience spans deep/reinforcement learning, trajectory optimization, CUDA programming, and performant C++ control code across quadrupeds, self-driving cars, surgical robots, and drones.
I’m advised by Prof. Aaron Johnson at the Robomechanics Lab. Right now, I’m researching differentiable-sim-based reinforcement learning for locomotion and manipulation, imitation learning for high-performance torque policies, and uncertainty quantification for world models.
previous role
-
08/25 — 01/26 San Jose, CA
Motion Planning & Controls Intern
Audi of America, Audi Automated Driving Development
- Implemented sampling-based MPC using CUDA and deployed on test drives.
- Added multi-threaded action scheduling for more consistent control signals.
- Designed a novel low-frequency MPPI algorithm for smoother, safer planning.
project highlights
-
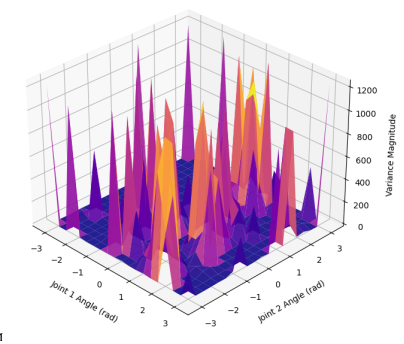 Fast Uncertainty-Aware Model-Based Reinforcement LearningEvidential deep learning enables single-forward-pass uncertainty quantification. This is useful for uncertainty-aware model predictive control of world models, where typical ensembling methods may be too expensive to run in real time.
-
 Generative Modeling for Fluid Dynamics SimulationFluid dynamics are expensive to simulate, so we turn to neural surrogates. Image generation methods such as diffusion and flow matching are appealing since fluid states act as 2D images.
-
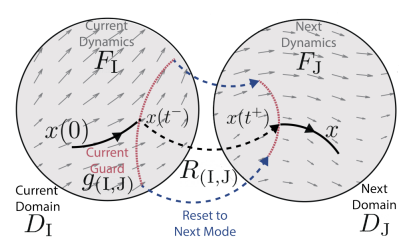 Heuristic-Admissible Hybrid iLQR using Multiple ShootingAugmenting the standard hybrid iLQR algorithm with multiple shooting enables more informative initial guesses for contact-rich planning.